第3章直線上の運動
3.6 Finding Velocity and Displacement from Acceleration3.6 加速度から速度と変位を求める
Learning Objectives学習目標
Learning Objectives学習目標
By the end of this section, you will be able to:
英語のヒント
この節を終えると、次のことができるようになる。
- Derive the kinematic equations for constant acceleration using integral calculus.
英語のヒント
積分を使って等加速度運動の式を導く。 - Use the integral formulation of the kinematic equations in analyzing motion.
英語のヒント
運動の分析に、積分で表した運動学の式を使う。 - Find the functional form of velocity versus time given the acceleration function.
英語のヒント
加速度関数から、速度を時間の関数として求める。 - Find the functional form of position versus time given the velocity function.
英語のヒント
速度関数から、位置を時間の関数として求める。
This section assumes you have enough background in calculus to be familiar with integration. In Instantaneous Velocity and Speed and Average and Instantaneous Acceleration we introduced the kinematic functions of velocity and acceleration using the derivative. By taking the derivative of the position function we found the velocity function, and likewise by taking the derivative of the velocity function we found the acceleration function. Using integral calculus, we can work backward and calculate the velocity function from the acceleration function, and the position function from the velocity function.
英語のヒント
この節は、積分に慣れているだけの微積分の基礎知識があることを前提とする。「瞬間速度と速さ」と「平均加速度と瞬間加速度」では、微分を使って運動学の速度関数と加速度関数を導入した。位置関数を微分して速度関数を求め、同じように速度関数を微分して加速度関数を求めた。積分を使えば、逆に加速度関数から速度関数を計算し、速度関数から位置関数を計算できる。
Kinematic Equations from Integral Calculus積分による運動学の式
Let’s begin with a particle with an acceleration a(t) which is a known function of time. Since the time derivative of the velocity function is acceleration,
英語のヒント
加速度a(t)が、既知の時間の関数で与えられる粒子から考えよう。速度関数の時間微分が加速度なので、
we can take the indefinite integral of both sides, finding
英語のヒント
両辺の不定積分を取ることができ、次の式を得る。
where C1 is a constant of integration. Since , the velocity is given by
英語のヒント
ここでC1は積分定数である。なので、速度は次の式で与えられる。
Similarly, the time derivative of the position function is the velocity function,
英語のヒント
同様に、位置関数の時間微分は速度関数である。
Thus, we can use the same mathematical manipulations we just used and find
英語のヒント
したがって、今行ったのと同じ数学的な操作を使うと、次の式を得る。
where C2 is a second constant of integration.
英語のヒント
ここでC2は二つ目の積分定数である。
We can derive the kinematic equations for a constant acceleration using these integrals. With a(t) = a a constant, and doing the integration in Equation 3.18, we find
英語のヒント
これらの積分を使い、等加速度運動の式を導ける。a(t) = aを一定とし、式3.18の積分を行うと、次の式を得る。
If the initial velocity is v(0) = v0, then
英語のヒント
初速度がv(0) = v0なら、
Then, C1 = v0 and
英語のヒント
したがってC1 = v0となり、
which is Equation 3.12. Substituting this expression into Equation 3.19 gives
英語のヒント
Doing the integration, we find
英語のヒント
積分を行うと、次の式を得る。
If x(0) = x0, we have
英語のヒント
x(0) = x0なら、
so, C2 = x0. Substituting back into the equation for x(t), we finally have
英語のヒント
よってC2 = x0である。x(t)の式へ戻して代入すると、最終的に次の式を得る。
Example 3.17例題 3.17
Motion of a Motorboatモーターボートの運動
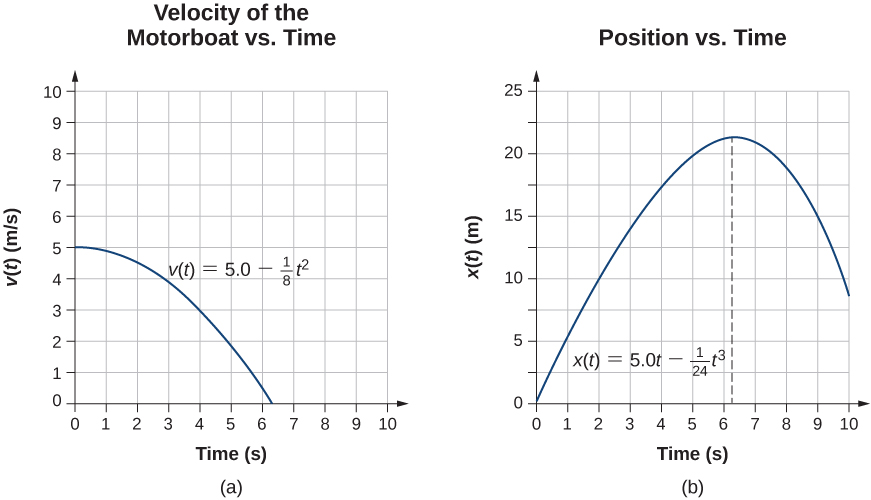
A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to accelerate opposite to the motion to arrive at the dock. Its acceleration is . (a) What is the velocity function of the motorboat? (b) At what time does the velocity reach zero? (c) What is the position function of the motorboat? (d) What is the displacement of the motorboat from the time it begins to accelerate opposite to the motion to when the velocity is zero? (e) Graph the velocity and position functions.
英語のヒント
モーターボートが一定の速度5.0 m/sで進んでいて、桟橋へ着くために運動と逆向きの加速を始める。加速度はである。(a)モーターボートの速度関数は何か。(b)どの時刻に速度が0になるか。(c)位置関数は何か。(d)運動と逆向きの加速を始めてから、速度が0になるまでの変位はいくらか。(e)速度関数と位置関数のグラフを描け。
Strategy方針
(a) To get the velocity function we must integrate and use initial conditions to find the constant of integration. (b) We set the velocity function equal to zero and solve for t. (c) Similarly, we must integrate to find the position function and use initial conditions to find the constant of integration. (d) Since the initial position is taken to be zero, we only have to evaluate the position function at the time when the velocity is zero.
英語のヒント
(a)速度関数を得るには積分を行い、初期条件から積分定数を求める。(b)速度関数を0と置き、tについて解く。(c)同様に積分して位置関数を求め、初期条件から積分定数を決める。(d)初期位置を0とするので、速度が0となる時刻での位置関数の値を求めるだけでよい。
Solution解答
We take t = 0 to be the time when the boat starts to accelerate opposite to the motion.
英語のヒント
ボートが運動と逆向きの加速を始める時刻をt = 0とする。
- From the functional form of the acceleration we can solve Equation 3.18 to get v(t):
英語のヒント
加速度の関数形から、式3.18を使ってv(t)を求められる。At t = 0 we have v(0) = 5.0 m/s = 0 + C1, so C1 = 5.0 m/s or .英語のヒント
t = 0ではv(0) = 5.0 m/s = 0 + C1なので、C1 = 5.0 m/s、すなわちとなる。 -
At t = 0, we set x(0) = 0 = x0, since we are only interested in the displacement from when the boat starts to accelerate opposite to the motion. We have
英語のヒント
運動と逆向きの加速を始めてからの変位だけを考えるため、t = 0でx(0) = 0 = x0とする。すると、Therefore, the equation for the position is英語のヒント
したがって位置の式は、 - Since the initial position is taken to be zero, we only have to evaluate the position function at the time when the velocity is zero. This occurs at t = 6.3 s. Therefore, the displacement is
英語のヒント
初期位置を0としたので、速度が0になる時刻で位置関数の値を求めればよい。その時刻はt = 6.3 sである。したがって変位は、
OpenStax / Rice University, University Physics Volume 1, CC BY 4.0. Source-book artwork retained. · CC BY 4.0 · Source出典

Figure 3.30図 3.30
(a) Velocity of the motorboat as a function of time. The motorboat decreases its velocity to zero in 6.3 s. At times greater than this, velocity becomes negative—meaning, the boat is reversing direction. (b) Position of the motorboat as a function of time. At t = 6.3 s, the velocity is zero and the boat has stopped. At times greater than this, the velocity becomes negative—meaning, if the boat continues to move with the same acceleration, it reverses direction and heads back toward where it originated.
英語のヒント
(a)モーターボートの速度と時間の関係。速度は6.3 sで0へ減少する。それ以後は負になり、ボートが向きを逆にすることを意味する。(b)モーターボートの位置と時間の関係。t = 6.3 sでは速度が0となり、ボートは停止する。それ以後は速度が負になる。つまり、同じ加速度で動き続けるなら、向きを逆にして出発位置へ戻っていく。
Significance意味の検討
The acceleration function is linear in time so the integration involves simple polynomials. In Figure 3.30, we see that if we extend the solution beyond the point when the velocity is zero, the velocity becomes negative and the boat reverses direction. This tells us that solutions can give us information outside our immediate interest and we should be careful when interpreting them.
英語のヒント
加速度関数は時間に対して1次式なので、積分に現れるのは簡単な多項式である。図3.30では、速度が0となる点を越えて解を延長すると、速度が負になり、ボートが向きを逆にすることが分かる。このことから、解は直接の関心の範囲外についても情報を与えうるので、解釈には注意が必要だと分かる。