第10章固定軸まわりの回転
Angular Acceleration角加速度
We have just discussed angular velocity for uniform circular motion, but not all motion is uniform. Envision an ice skater spinning with his arms outstretched—when he pulls his arms inward, his angular velocity increases. Or think about a computer’s hard disk slowing to a halt as the angular velocity decreases. We will explore these situations later, but we can already see a need to define an angular acceleration for describing situations where changes. The faster the change in , the greater the angular acceleration. We define the instantaneous angular acceleration as the derivative of angular velocity with respect to time:
英語のヒント
等速円運動の角速度を扱ってきたが、すべての運動が一様とは限らない。腕を広げて回転するアイススケート選手を思い浮かべよう。腕を内側へ引くと、角速度が増す。また、角速度が減って停止に至るコンピューターのハードディスクを考えてもよい。これらは後で詳しく調べるが、が変化する状況を記述するには、角加速度を定義する必要があると分かる。の変化が速いほど角加速度は大きい。瞬間角加速度を、角速度の時間微分として定義する。
where we have taken the limit of the average angular acceleration, as .
英語のヒント
ここでは、平均角加速度の、における極限を取った。
The units of angular acceleration are (rad/s)/s, or .
英語のヒント
角加速度の単位は(rad/s)/s、すなわちである。
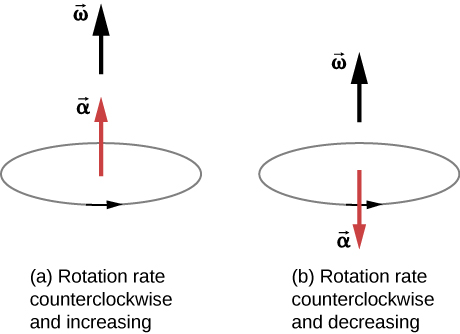
In the same way as we defined the vector associated with angular velocity , we can define , the vector associated with angular acceleration (Figure 10.7). If the angular velocity is along the positive z-axis, as in Figure 10.5, and is positive, then the angular acceleration is positive and points along the axis. Similarly, if the angular velocity is along the positive z-axis and is negative, then the angular acceleration is negative and points along the axis.
英語のヒント
OpenStax / Rice University, University Physics Volume 1, CC BY 4.0. Source-book artwork retained. · CC BY 4.0 · Source出典

Figure 10.7図 10.7
The rotation is counterclockwise in both (a) and (b) with the angular velocity in the same direction. (a) The angular acceleration is in the same direction as the angular velocity, which increases the rotation rate. (b) The angular acceleration is in the opposite direction to the angular velocity, which decreases the rotation rate.
英語のヒント
(a)、(b)とも反時計回りで、角速度は同じ向きである。(a)角加速度は角速度と同じ向きで、回転の速さを増す。(b)角加速度は角速度と逆向きで、回転の速さを減らす。
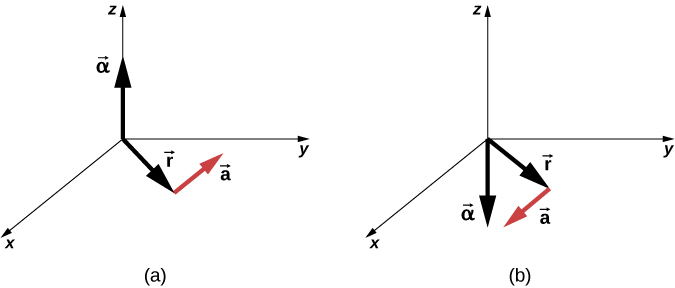
We can express the tangential acceleration vector as a cross product of the angular acceleration and the position vector. This expression can be found by taking the time derivative of and is left as an exercise:
英語のヒント
接線加速度ベクトルは、角加速度と位置ベクトルの外積として表せる。この式はを時間で微分して得られる。導出は演習とする。
(10.7)
The vector relationships for the angular acceleration and tangential acceleration are shown in Figure 10.8.
英語のヒント
角加速度と接線加速度のベクトルの関係を図10.8に示す。
OpenStax / Rice University, University Physics Volume 1, CC BY 4.0. Source-book artwork retained. · CC BY 4.0 · Source出典

Figure 10.8図 10.8
(a) The angular acceleration is the positive z-direction and produces a tangential acceleration in a counterclockwise sense. (b) The angular acceleration is in the negative z-direction and produces a tangential acceleration in the clockwise sense.
英語のヒント
(a)角加速度はzの正方向で、反時計回りの接線加速度を生じさせる。(b)角加速度はzの負方向で、時計回りの接線加速度を生じさせる。
We can relate the tangential acceleration of a point on a rotating body at a distance from the axis of rotation in the same way that we related the tangential speed to the angular velocity. If we differentiate Equation 10.4 with respect to time, noting that the radius r is constant, we obtain
英語のヒント
回転物体上で回転軸からある距離にある点の接線加速度も、接線方向の速さと角速度を関係づけたのと同じように扱える。半径rが一定であることに注意して、式10.4を時間で微分すると、次を得る。
Thus, the tangential acceleration is the radius times the angular acceleration. Equation 10.4 and Equation 10.8 are important for the discussion of rolling motion (see Angular Momentum).
英語のヒント
Let’s apply these ideas to the analysis of a few simple fixed-axis rotation scenarios. Before doing so, we present a problem-solving strategy that can be applied to rotational kinematics: the description of rotational motion.
英語のヒント
これらの考えを、固定軸の周りの回転の簡単な事例に適用しよう。その前に、回転の運動学、つまり回転運動の記述に使える問題解法の方針を示す。
Now let’s apply this problem-solving strategy to a few specific examples.
英語のヒント
この解法の方針を、いくつかの具体例へ適用しよう。
Example 10.2例題 10.2
A Spinning Bicycle Wheel回転する自転車の車輪
A bicycle mechanic mounts a bicycle on the repair stand and starts the rear wheel spinning from rest to a final angular velocity of 250 rpm in 5.00 s. (a) Calculate the average angular acceleration in . (b) If she now hits the brakes, causing an angular acceleration of −87.3 , how long does it take the wheel to stop?
英語のヒント
自転車整備士が自転車を修理台へ取り付け、静止していた後輪を回し始め、5.00 sで角速度250 rpmにする。(a)平均角加速度をで計算せよ。(b)次にブレーキをかけ、−87.3 の角加速度を生じさせると、車輪は何秒で止まるか。
Strategy方針
The average angular acceleration can be found directly from its definition because the final angular velocity and time are given. We see that and is 5.00 s. For part (b), we know the angular acceleration and the initial angular velocity. We can find the stopping time by using the definition of average angular acceleration and solving for , yielding
英語のヒント
最終角速度と時間が与えられているので、平均角加速度は定義から直接求められる。で、は5.00 sである。(b)では角加速度と初めの角速度が分かっている。平均角加速度の定義をについて解くことで、停止までの時間を求められる。
Solution解答
- Entering known information into the definition of angular acceleration, we get
英語のヒント
既知の情報を角加速度の定義へ代入すると、次を得る。Because is in revolutions per minute (rpm) and we want the standard units of for angular acceleration, we need to convert from rpm to rad/s:英語のヒント
は回転毎分(rpm)で与えられているが、角加速度の標準単位を使いたい。そのため、rpmをrad/sへ換算する必要がある。Entering this quantity into the expression for , we get英語のヒント
この量をの式へ代入すると、次を得る。 - Here the angular velocity decreases from 26.2 rad/s (250 rpm) to zero, so that is −26.2 rad/s, and is given to be –87.3 . Thus,
英語のヒント
角速度は26.2 rad/s(250 rpm)から0へ減るので、は−26.2 rad/sとなる。は−87.3 と与えられている。したがって、
Significance考察
Note that the angular acceleration as the mechanic spins the wheel is small and positive; it takes 5 s to produce an appreciable angular velocity. When she hits the brake, the angular acceleration is large and negative. The angular velocity quickly goes to zero.
英語のヒント
整備士が車輪を回すときの角加速度は小さく、正である。かなりの角速度に達するのに5 sかかる。ブレーキをかけると、角加速度は大きく、負になる。角速度はすぐに0となる。
Example 10.3例題 10.3
Wind Turbine風力タービン
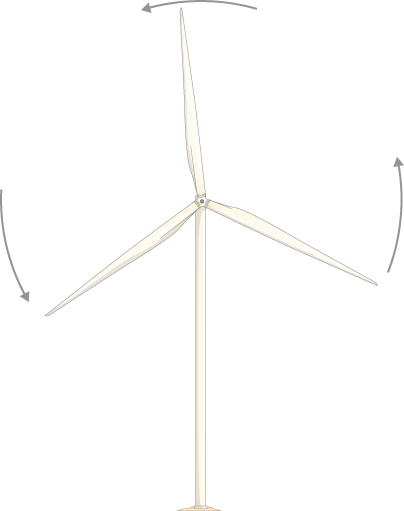
A wind turbine (Figure 10.10) in a wind farm is being shut down for maintenance. It takes 30 s for the turbine to go from its operating angular velocity to a complete stop in which the angular velocity function is , where is the time in seconds. If the turbine is rotating counterclockwise looking into the page, (a) what are the directions of the angular velocity and acceleration vectors? (b) What is the average angular acceleration? (c) What is the instantaneous angular acceleration at
英語のヒント
風力発電所のタービン(図10.10)を、保守作業のために停止させる。稼働時の角速度から完全に止まるまで30 sかかり、角速度の関数はで与えられる。は秒で測った時間である。紙面を正面から見て反時計回りに回るとき、(a)角速度ベクトルと角加速度ベクトルの向きは何か。(b)平均角加速度は何か。(c)における瞬間角加速度は何か。
OpenStax / Rice University, University Physics Volume 1, CC BY 4.0. Source-book artwork retained. · CC BY 4.0 · Source出典

Figure 10.10図 10.10
A wind turbine that is rotating counterclockwise, as seen head on.
英語のヒント
正面から見ると反時計回りに回転する風力タービン。
Strategy方針
- We are given the rotational sense of the turbine, which is counterclockwise in the plane of the page. Using the right hand rule (Figure 10.5), we can establish the directions of the angular velocity and acceleration vectors.
英語のヒント
タービンの回転の向きは、紙面内で反時計回りと与えられている。右手の法則(図10.5)から、角速度ベクトルと角加速度ベクトルの向きを決められる。 - We calculate the initial and final angular velocities to get the average angular acceleration. We establish the sign of the angular acceleration from the results in (a).
英語のヒント
初めと最後の角速度を計算して、平均角加速度を得る。角加速度の符号は(a)の結果から決める。 - We are given the functional form of the angular velocity, so we can find the functional form of the angular acceleration function by taking its derivative with respect to time.
英語のヒント
角速度の関数の形が与えられているので、それを時間で微分すれば、角加速度の関数の形を求められる。
Solution解答
- Since the turbine is rotating counterclockwise, angular velocity points out of the page. But since the angular velocity is decreasing, the angular acceleration points into the page, in the opposite sense to the angular velocity.
英語のヒント
タービンが反時計回りに回るので、角速度は紙面から手前へ向く。しかし、角速度は減っているため、角加速度は角速度と逆向き、つまり紙面の奥へ向く。 - The initial angular velocity of the turbine, setting . The final angular velocity is zero, so the average angular acceleration is
英語のヒント
タービンの初めの角速度は、と置いて得られる。最後の角速度は0なので、平均角加速度は次のようになる。 - Taking the derivative of the angular velocity with respect to time gives
英語のヒント
角速度を時間で微分すると、を得る。
Significance考察
We found from the calculations in (a) and (b) that the angular acceleration and the average angular acceleration are negative. The turbine has an angular acceleration in the opposite sense to its angular velocity.
英語のヒント
(a)と(b)の計算から、角加速度と平均角加速度は負であると分かった。タービンの角加速度は角速度と逆向きである。
We now have a basic vocabulary for discussing fixed-axis rotational kinematics and relationships between rotational variables. We discuss more definitions and connections in the next section.
英語のヒント
固定軸の周りの回転の運動学と、回転を表す量の関係を論じるための基本用語がそろった。次節では、さらに定義や関係を扱う。